DEMO: Dynamically Feasible Mission Planning And Control
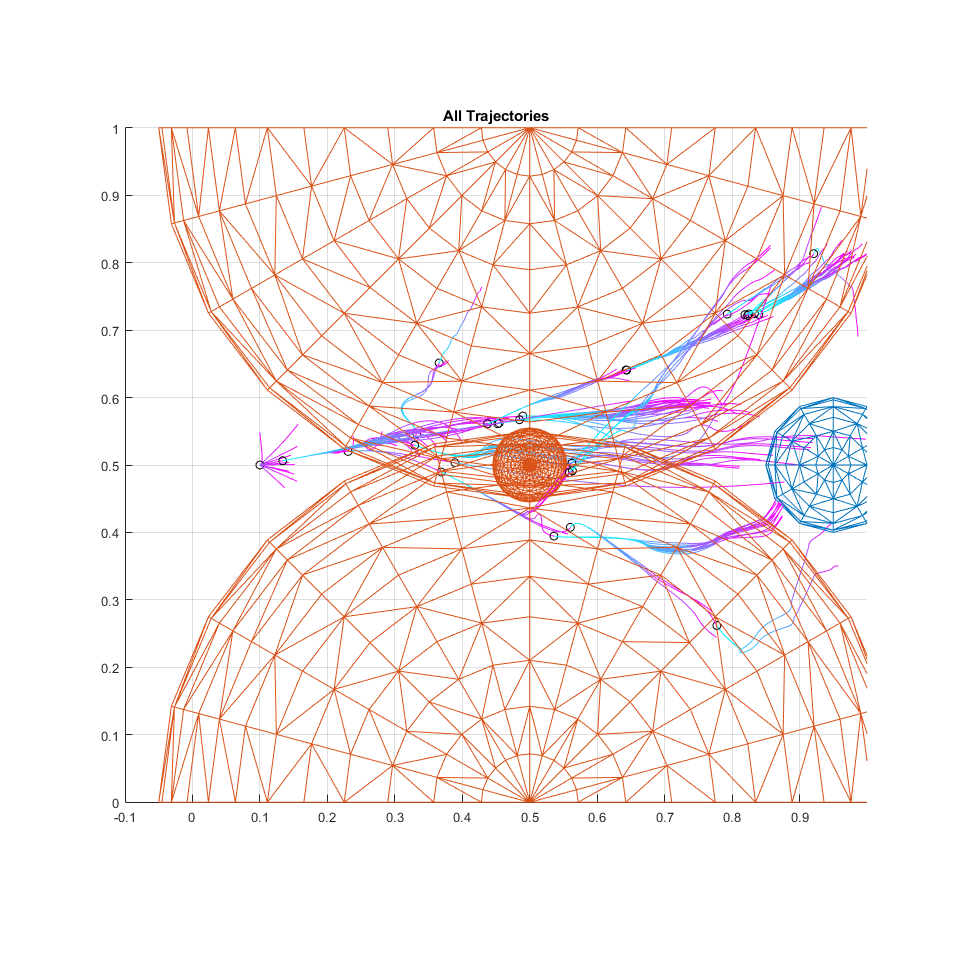
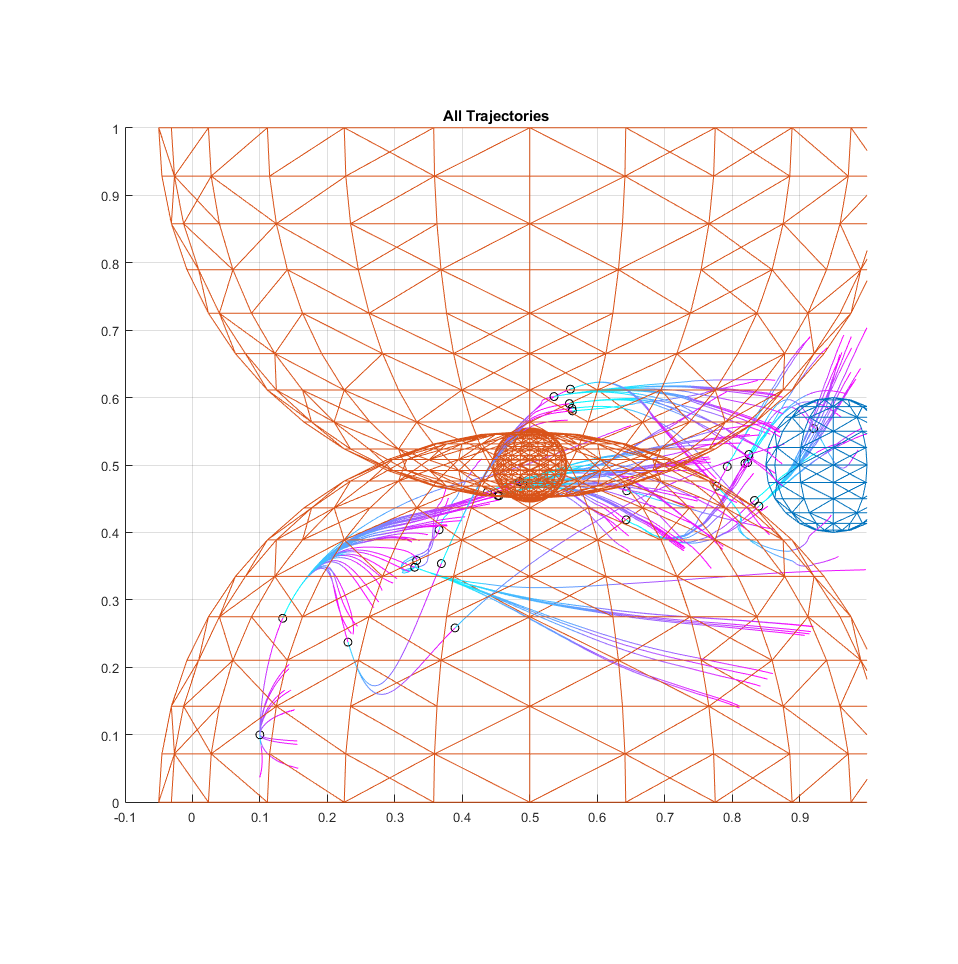
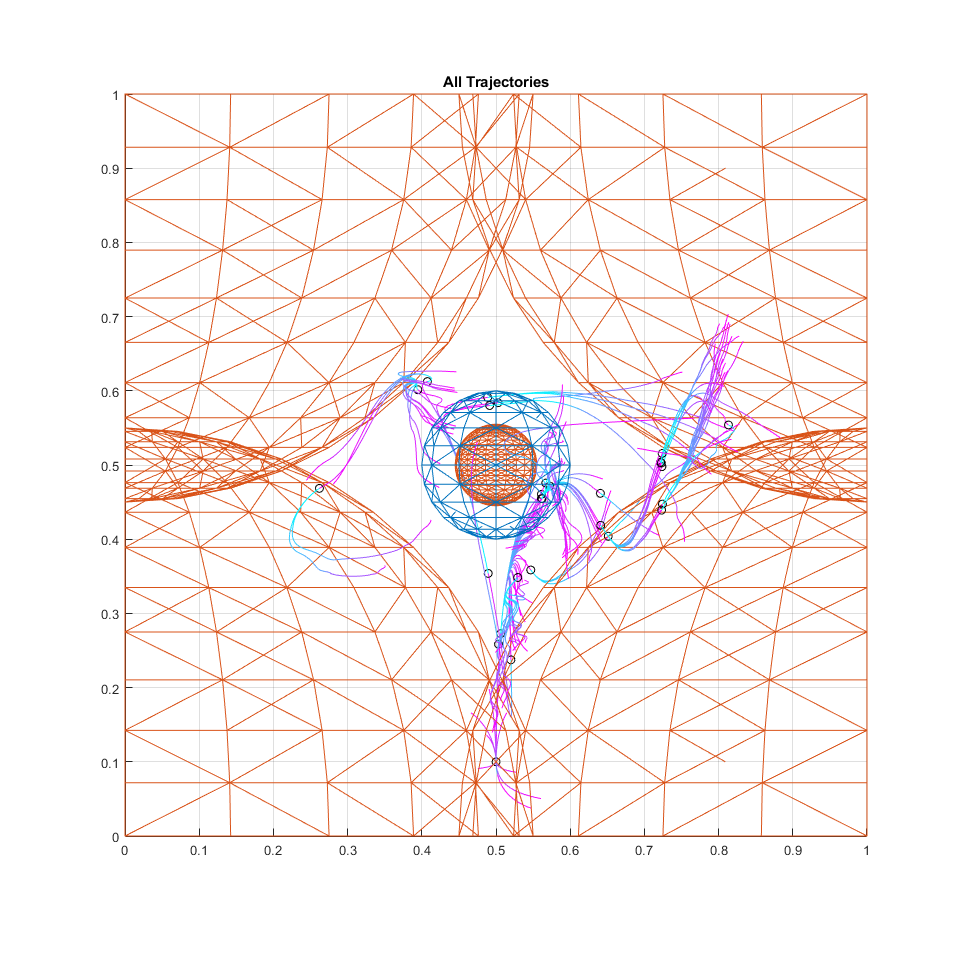
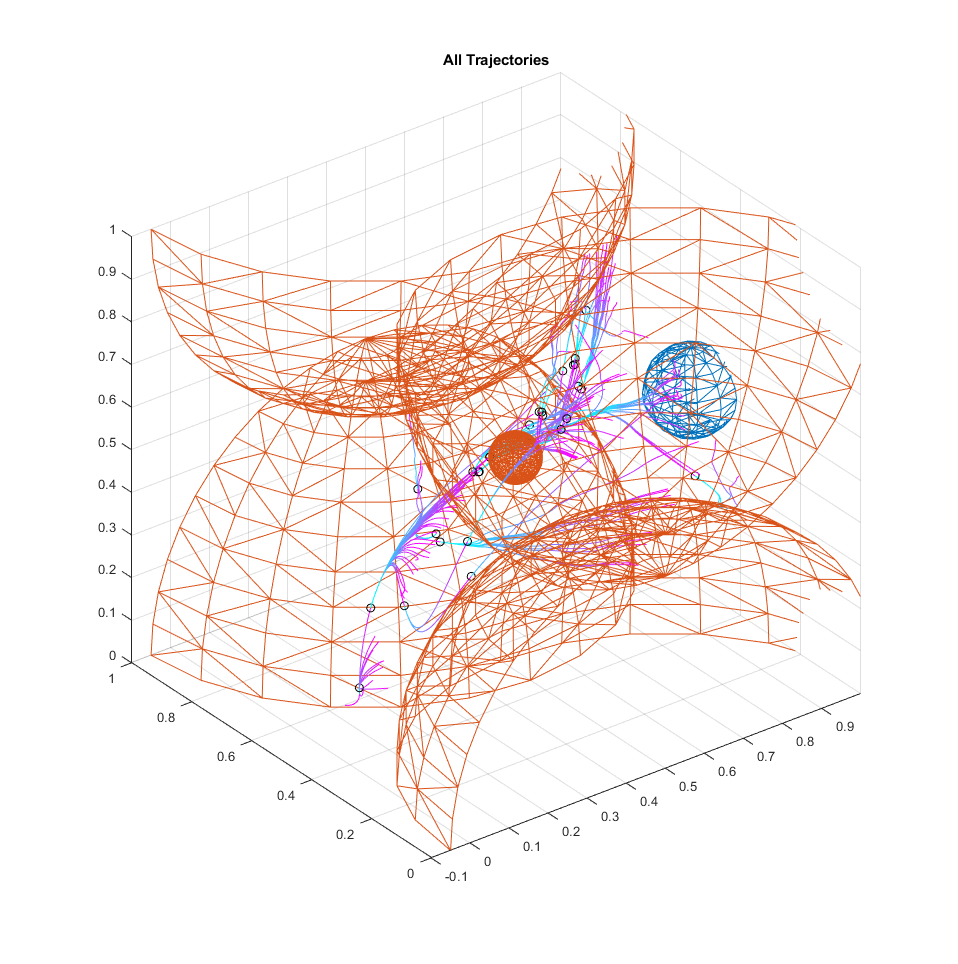
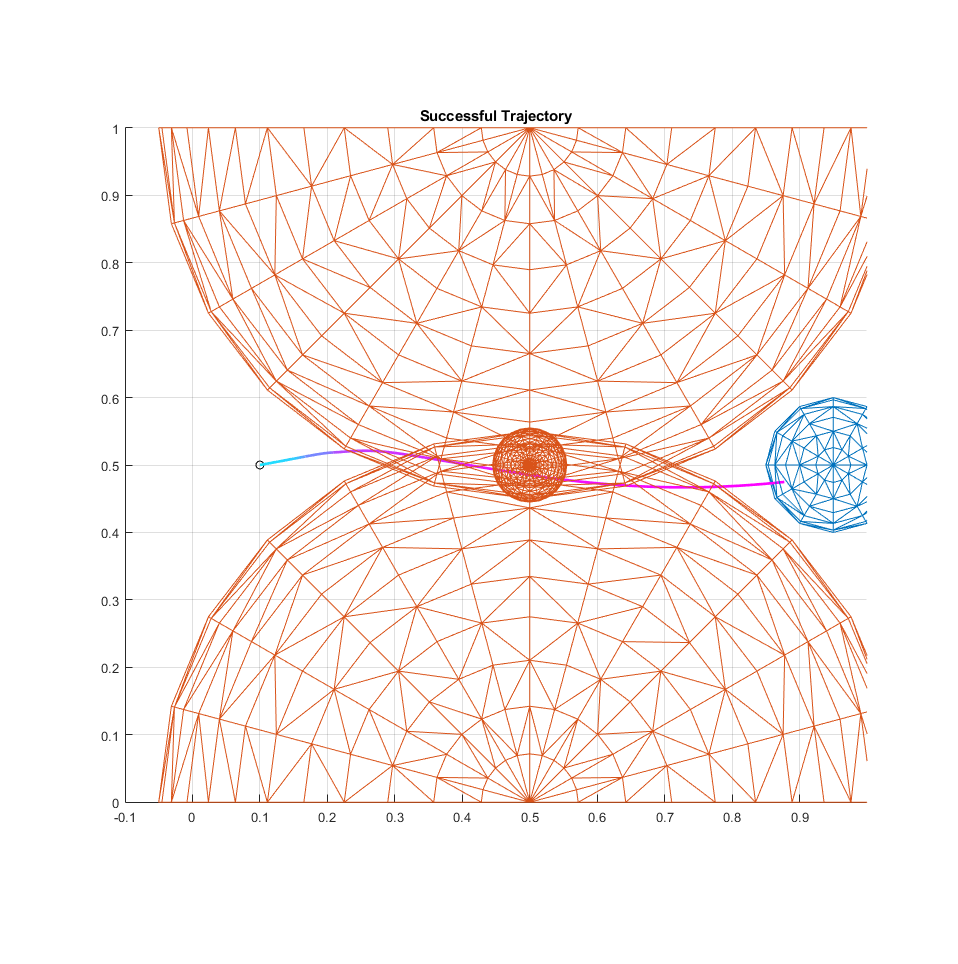
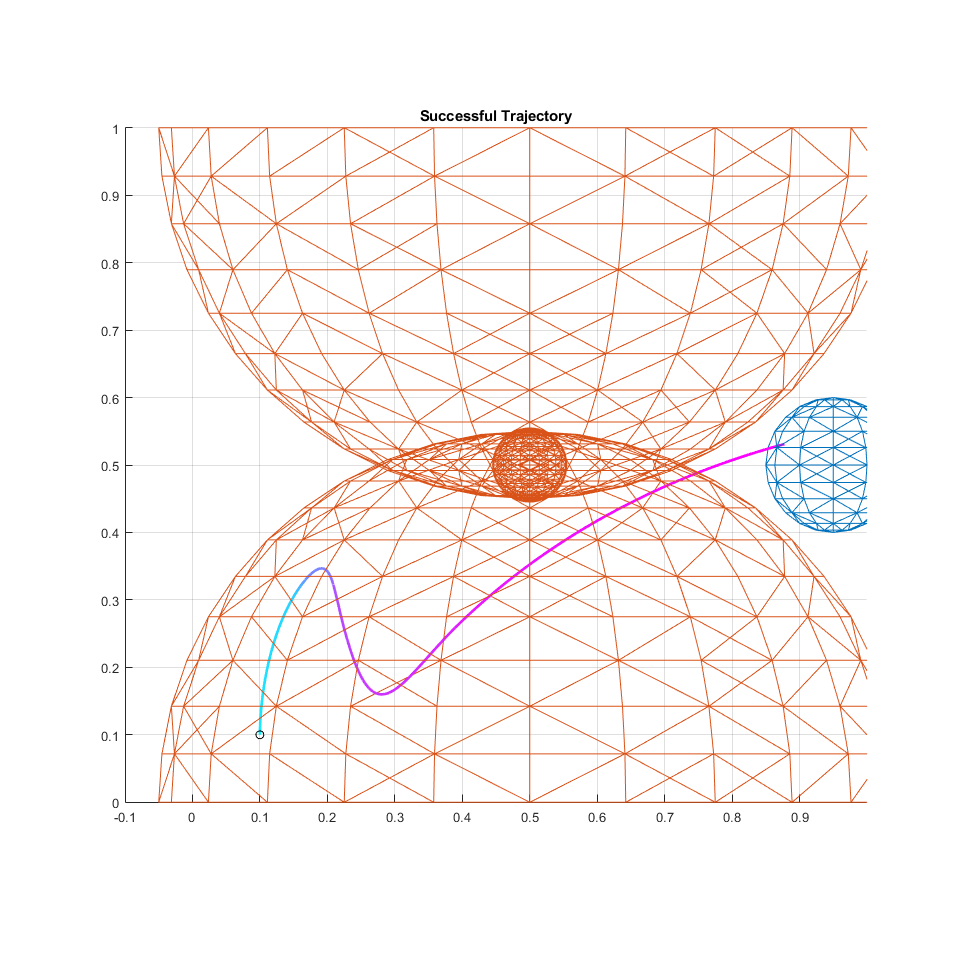
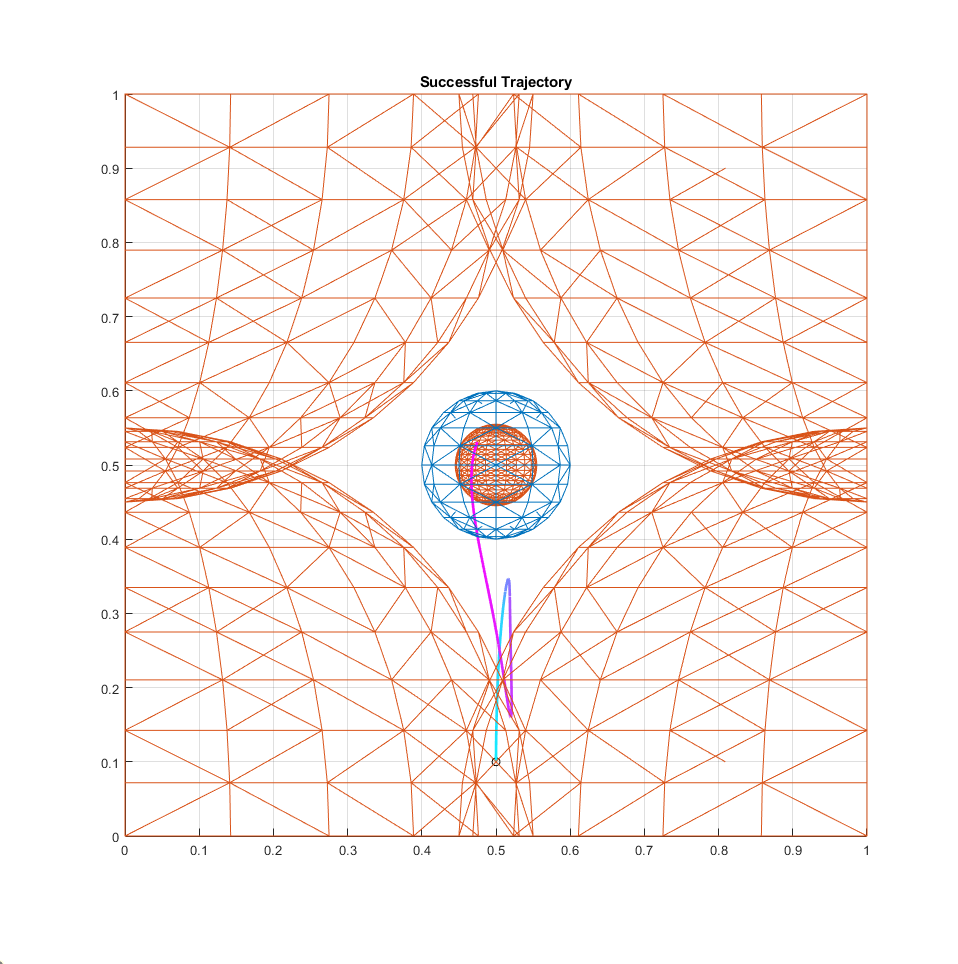
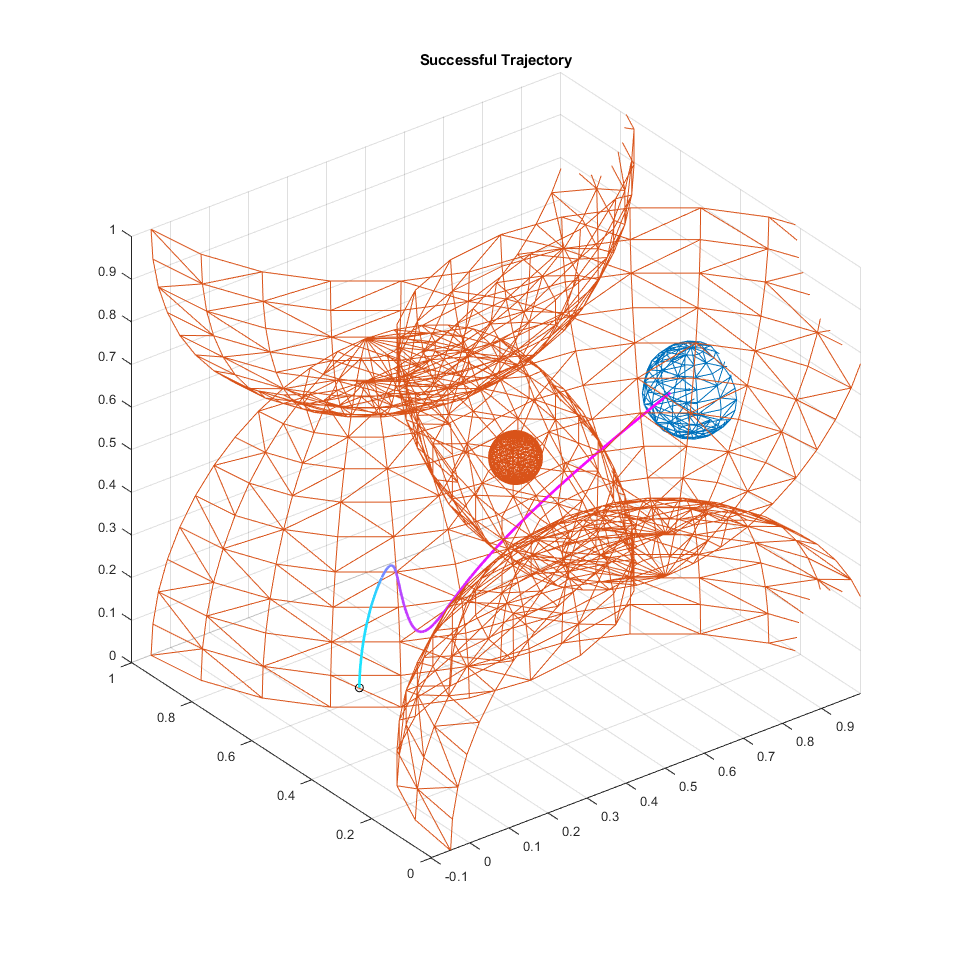
Below is a sample of our autonomous systems planning and control capability, specifically probabilistic (sampling) trajectory generation for 6DOF quadrotor flight dynamics driven by a nonlinear backstepping controller. Orange meshes are keep-out regions, the blue mesh is the goal region, black circles represent valid intermediate states from the initial point on the opposite side from the goal region, and the blue-purple lines represent dynamically realizable trajectories between intermediate states with blue as the start of the trajectory.
Example Applications:
- Autonomous robotics mission/path planning
- Nonlinear system control
- Constrained problems requiring convergence guarantees
- Missions requiring multiple and/or redundant plans, e.g. variable/dynamic keep-out constraints